Community Bonding: Weeks 1 & 2
I got selected for GSoC 2026 with JdeRobot, and the first two weeks had one clear goal: understand the platform deeply enough to know exactly what will break when I change it. Before you can optimize a 29.5 GB Docker image, you need to know why every gigabyte is there. That is what Weeks 1 and 2 were for — not guessing, but measuring.
My project is Project #7 — Optimizing RoboticsAcademy Infrastructure. It has three goals. First, reduce the size and build time of the jderobot/robotics-academy Docker image, which currently sits at 29.5 GB uncompressed — a serious barrier for students and contributors with limited disk space or slow internet. The primary targets are OMPL (takes 34 minutes to compile from source, leaves 1.5 GB of build artifacts on disk) and Aerostack2 (takes nearly 14 minutes to build, leaves 463 MB of dead weight). Second, migrate the runtime from Docker to a daemonless, rootless Podman architecture for better security, including GPU acceleration via the Container Device Interface (CDI). Third, restructure the build into a proper multi-stage pipeline so compiler toolchains, source trees, and build artifacts never make it into the final runtime image. These two weeks were about collecting the baseline measurements that will prove the optimization worked.
Test Environment
All build time measurements in this post were recorded on a Lenovo Legion 5 with AMD Ryzen 5 4600H, NVIDIA GTX 1650, and 16 GB RAM running Kubuntu Linux. These numbers represent a mid-range developer machine — not a CI server — so they reflect realistic local build times a contributor would experience.
The Mentor Team
Before I get into the work, I want to introduce the mentors I’m working with — they’ve been genuinely helpful from the start.
- David Pascual-Hernández — He leads our weekly syncs, keeps the project direction on track, and is the main person I check in with when I need to validate an approach.
- Javier I. — Most of the deeper architecture and code questions go to Javier. Whenever I’m confused about how something fits together in the stack, he’s the one I ask.
- Md. Shariar Kabir — Official mentor for this project. Has been available throughout the bonding period and brings direct experience with the JdeRobot infrastructure.
- Nikhil Gupta — official mentor, has been available for questions during the bonding period.
Week 1 — Setting Up Locally
The first priority was getting the full stack running locally on my machine — a Lenovo Legion 5 with Ryzen 5 4600H, GTX 1650, and 16 GB RAM running Kubuntu. This meant pulling jderobot/robotics-academy:latest (29.5 GB) and jderobot/robotics-database:latest (486 MB), setting up the NVIDIA Container Toolkit, configuring the NVIDIA runtime in /etc/docker/daemon.json, and verifying that Django was reachable on port 7164.
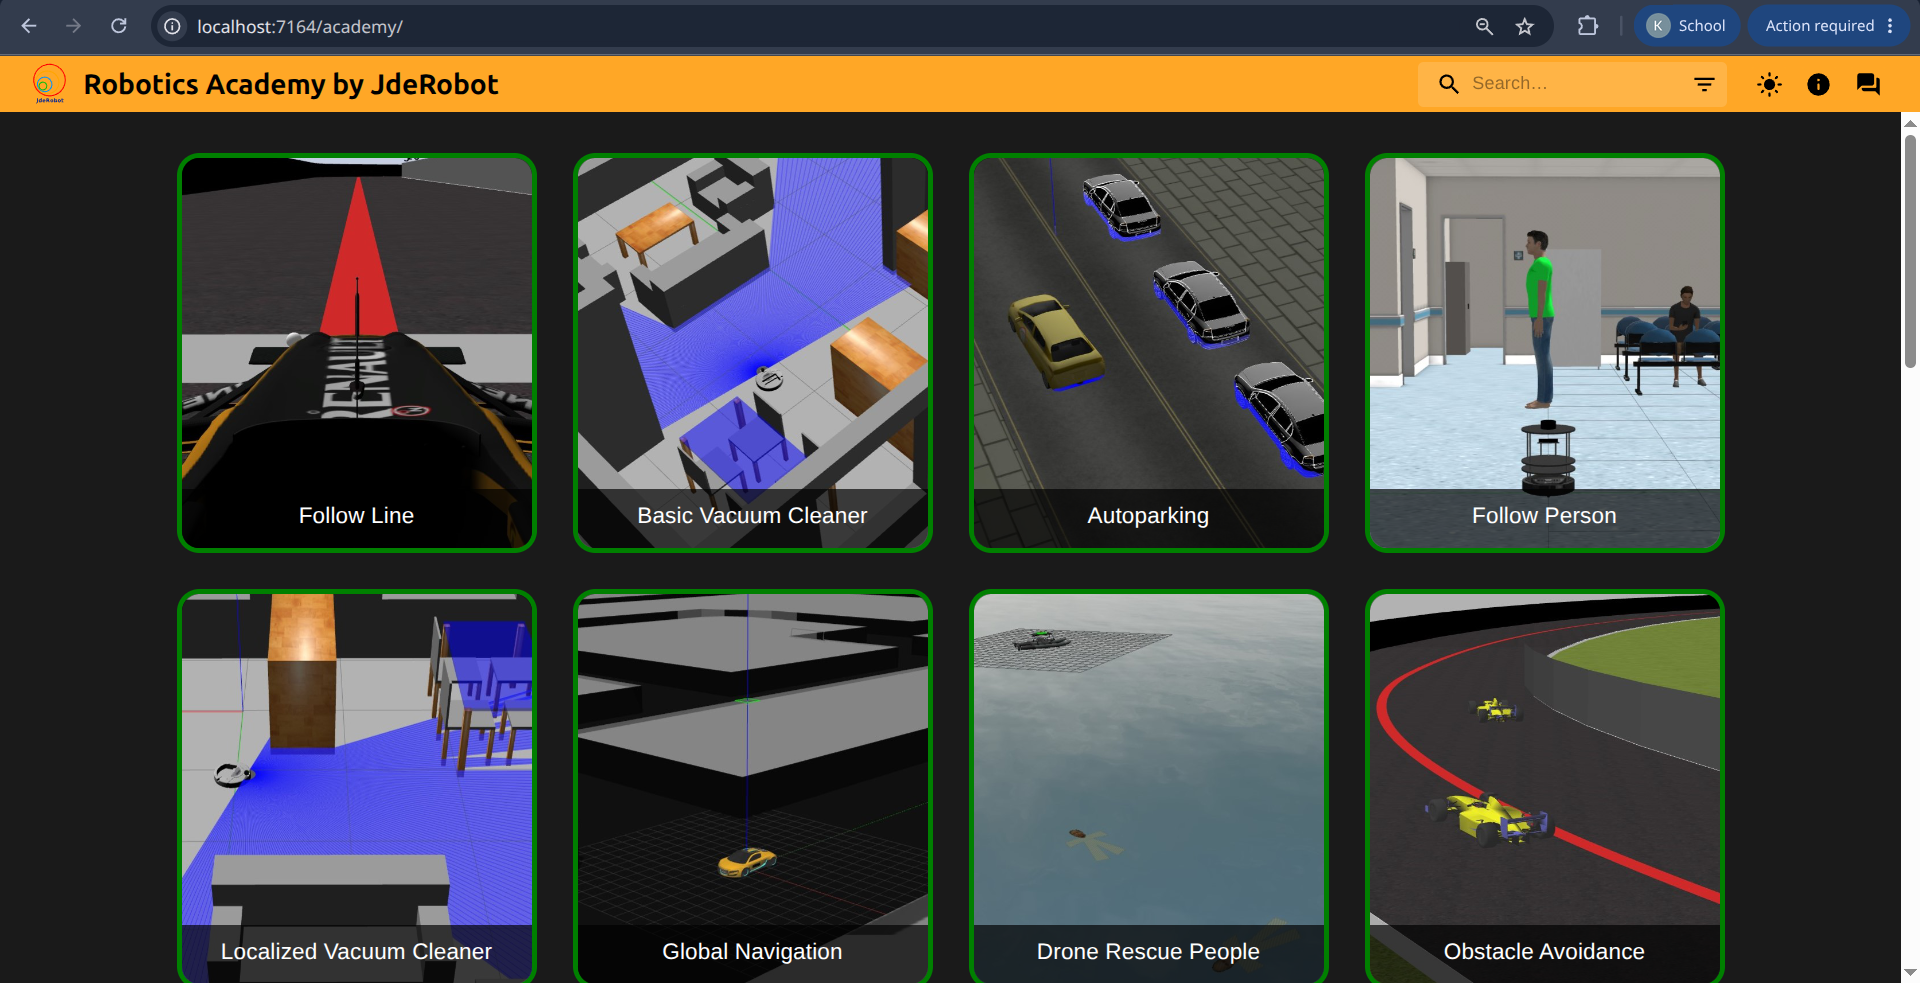
The kickoff meeting with David covered project milestones and set expectations for the coding period. One piece of advice that turned out to be useful early: do not assume this stack works like a standard web application. The Django server is not what runs student code — that distinction became important in Week 2.
Week 2 — Looking at the Dockerfile
With the environment confirmed working, Week 2 was entirely about measurement. The production image is built from three Dockerfiles in sequence: Dockerfile.dependencies_humble builds the base from nvidia/opengl:1.2-glvnd-runtime-ubuntu22.04, Dockerfile.humble layers the RoboticsAcademy application on top, and Dockerfile.database builds an independent PostgreSQL image. The first question was simple: where does the 29.5 GB actually come from?
I ran a few grep commands directly on the file to get a concrete count.
# Count all layer-altering instructions
grep -cE '^(RUN|COPY|ADD)' Dockerfile.dependencies_humble

# Count separate apt-get install blocks
grep -c 'apt-get install' Dockerfile.dependencies_humble

# Count cache purges
grep -c 'rm -rf /var/lib/apt/lists/\*' Dockerfile.dependencies_humble
| Metric | Count |
|---|---|
Total layer-altering instructions (RUN, COPY, ADD) |
59 |
Independent apt-get install blocks |
17 |
rm -rf /var/lib/apt/lists/* cache purges |
12 |
| Net leaking layers | ≥ 4 |
The static grep analysis gave us the structure of the problem — 59 layer-altering instructions, 17 separate apt install blocks, and at least 4 layers leaking apt cache. But structure alone does not tell you where the gigabytes and the minutes go. That required running actual measurements against the pulled image, which the sections below document in full.
Current Image Size Baseline
The current production image jderobot/robotics-academy:latest has the following measured profile:
- Total uncompressed size: 29.5 GB
- Total layers: 30
- Build pipeline: 3 Dockerfiles in sequence
Dockerfile.dependencies_humble— builds onnvidia/opengl:1.2-glvnd-runtime-ubuntu22.04Dockerfile.humble— builds on top of the dependencies imageDockerfile.database— independent, builds onpostgres:18, final size 486 MB
These numbers were obtained by running docker images and docker history --no-trunc --format against the pulled production image.
Layer-by-Layer Size Breakdown
Running docker history jderobot/robotics-academy:latest --no-trunc --format "\t" | sort -h -r produces a ranked list of every layer by size. The top 30 layers sorted largest first:
| Rank | Layer Size | What It Does | Which Dockerfile |
|---|---|---|---|
| 1 | 7.9 GB | pip install torch with CUDA 12.8 support | Dockerfile.dependencies_humble |
| 2 | 4.61 GB | git clone RoboticsInfrastructure (shallow, –depth 1) | Dockerfile.humble |
| 3 | 2.91 GB | mv packages from clone into ROS2 workspace | Dockerfile.humble |
| 4 | 2.39 GB | install-ompl-ubuntu.sh — compile OMPL from source | Dockerfile.dependencies_humble |
| 5 | 1.87 GB | apt-get install gazebo11 + gstreamer plugins | Dockerfile.dependencies_humble |
| 6 | 1.78 GB | yarn install && yarn run build React frontend | Dockerfile.humble |
| 7 | 1.3 GB | pip install ML packages (onnxruntime-gpu, opencv, numpy) | Dockerfile.dependencies_humble |
| 8 | 628 MB | colcon build && colcon build IndustrialRobots workspace | Dockerfile.dependencies_humble |
| 9 | 594 MB | apt-get install ros-humble-ros-base + rviz2 + colcon | Dockerfile.dependencies_humble |
| 10 | 580 MB | apt-get install libpcl-dev + ros-humble-pcl-ros | Dockerfile.dependencies_humble |
| 11 | 559 MB | apt-get install lxde-common desktop environment | Dockerfile.dependencies_humble |
| 12 | 495 MB | apt-get install build-essential git cmake vim gnupg | Dockerfile.dependencies_humble |
| 13 | 468 MB | apt-get install ros-humble-ros-gzharmonic | Dockerfile.dependencies_humble |
| 14 | 385 MB | apt-get install libglvnd0 libgl1 libegl1 NVIDIA GL | Dockerfile.dependencies_humble |
| 15 | 384 MB | colcon build –symlink-install Aerostack2 workspace | Dockerfile.dependencies_humble |
| 16 | 375 MB | apt-get install libeigen3 + 40 ros-humble packages + MoveIt | Dockerfile.dependencies_humble |
| 17 | 292 MB | git clone IndustrialRobots | Dockerfile.dependencies_humble |
| 18 | 279 MB | apt-get install nodejs + yarn | Dockerfile.dependencies_humble |
| 19 | 267 MB | apt-get install gz-harmonic Gazebo Harmonic | Dockerfile.dependencies_humble |
| 20 | 224 MB | git clone RoboticsAcademy | Dockerfile.humble |
| 21 | 163 MB | apt-get install xvfb x11vnc xterm VNC and X11 stack | Dockerfile.dependencies_humble |
| 22 | 119 MB | colcon build –symlink-install RoboticsAcademy workspace | Dockerfile.humble |
| 23 | 115 MB | git clone aerostack2 -b robotics-academy-fix | Dockerfile.dependencies_humble |
| 24 | 105 MB | add-apt-repository ppa:openrobotics/gazebo11-gz-cli | Dockerfile.dependencies_humble |
| 25 | 94.5 MB | Install VirtualGL and TurboVNC | Dockerfile.dependencies_humble |
| 26 | 79 MB | apt-get install postgresql-18 | Dockerfile.dependencies_humble |
| 27 | 77.8 MB | Base Ubuntu 22.04 layer | base image |
| 28 | 69.9 MB | apt-get install tmux ros-dev-tools python3-pip | Dockerfile.dependencies_humble |
| 29 | 64.1 MB | pip install –upgrade pip wheel setuptools selenium | Dockerfile.dependencies_humble |
| 30 | 63.1 MB | mv /opt/jderobot/resources /resources | Dockerfile.humble |
Understanding Ghost Layers
A ghost layer is data that appears to have been cleaned up but is permanently baked into the image. In Docker, every RUN instruction creates a new layer. If layer 2 clones a 4.61 GB repository and layer 3 moves files out of it with mv, the original 4.61 GB from layer 2 never disappears — it stays in the image forever even though it looks like it was moved. The RoboticsInfrastructure clone in Dockerfile.humble follows exactly this pattern: layer 2 clones 4.61 GB, layer 3 moves 2.91 GB of it elsewhere, and both layers remain permanently in the image. The fix is to combine the clone and all subsequent mv operations into a single RUN instruction so Docker only records the final state.
Measured Build Times for Key Layers
To understand where build time is actually spent, each expensive layer was measured in isolation by running it inside the existing production container using time docker run --rm --entrypoint bash. This avoids a full 3-hour rebuild while giving accurate per-component timings on the same hardware.
| Component | Measured Build Time | What Was Built | How It Was Measured |
|---|---|---|---|
| OMPL | 34 minutes 16 seconds | Full C++ library + complete Python bindings compiled from source at commit 0f990886 | time docker run with full cmake + make update_bindings + make + make install |
| Aerostack2 | 13 minutes 52 seconds | 20 packages built successfully with correct COLCON_IGNORE files (6 packages skipped as per Dockerfile) | time docker run with colcon build –cmake-args -DCMAKE_BUILD_TYPE=Release |
| React frontend | 3 minutes 20 seconds | yarn install (88 seconds) + webpack production build (79 seconds) | time docker run with yarn install && yarn run build |
| IndustrialRobots | 3 minutes 8 seconds | Full git clone (no –depth 1) + double colcon build of 59 packages across both passes | time docker run clone + both colcon passes |
All times measured on Lenovo Legion 5 (Ryzen 5 4600H, GTX 1650, 16 GB RAM). The OMPL measurement is the most significant — 34 minutes for a single component means any change to a layer before OMPL in Dockerfile.dependencies_humble invalidates the cache and forces a full 34-minute recompile of that layer alone, with all subsequent layers also rebuilding.
Full Cold Build Measurement
After measuring individual components in isolation, a complete cold
build of both Dockerfiles was performed with --no-cache to get the
true end-to-end baseline. All measurements on Lenovo Legion 5,
Ryzen 5 4600H, GTX 1650, 16 GB RAM, Kubuntu.
Dockerfile.dependencies_humble — Full Build
Total time: 72 minutes 17 seconds
Complete per-layer breakdown ranked by time:
| Step | Time | Instruction |
|---|---|---|
| [64/70] | 26m56s | ./install-ompl-ubuntu.sh --github --python |
| [23/70] | 7m23s | pip install torch --extra-index-url .../cu128 |
| [45/70] | 5m58s | colcon build --symlink-install Aerostack2 |
| [44/70] | 5m54s | apt-get install libeigen3 + 40 ros-humble packages + MoveIt |
| [21/70] | 3m35s | pip install onnxruntime-gpu opencv numpy ML stack |
| [55/70] | 2m26s | colcon build && colcon build IndustrialRobots double pass |
| [4/70] | 2m34s | apt-get install ros-humble-ros-base + rviz2 + rosdep |
| [17/70] | 2m33s | apt-get install lxde-common |
| [6/70] | 2m29s | apt-get install gazebo11 + gstreamer plugins |
| [8/70] | 1m59s | apt-get install gz-harmonic |
| All remaining layers | ~10m | Small apt/pip/git/config steps |
OMPL alone accounts for 37.2% of the entire Step 1 build time.
Dockerfile.humble — Full Build
Total time: 30 minutes 6 seconds
| Step | Time | Instruction |
|---|---|---|
| [2/20] | 23m27s | git clone RoboticsInfrastructure --depth 1 |
| [17/20] | 1m44s | yarn install && yarn run build React frontend |
| [10/20] | 1m32s | git clone RoboticsAcademy --depth 1 |
| [14/20] | 1m32s | colcon build --symlink-install /home/ws |
| All remaining | ~1m | mv, chmod, zip, config steps |
The RoboticsInfrastructure clone took 23 minutes 27 seconds — 78% of the entire Step 2 build time — on a home internet connection. This is pure network latency with zero CPU involvement.
Combined Total
| Time | |
|---|---|
| Dockerfile.dependencies_humble | 72m17s |
| Dockerfile.humble | 30m06s |
| Dockerfile.database | 27s |
| Total cold build | 102m50s |
This is the before-baseline. Every optimization in this project will
be measured against this number. The difference between this 102-minute
local build and the ~45-minute build on institutional infrastructure is
almost entirely explained by network speed on two layers: the PyTorch
download (7m23s locally, ~1-2m on fast connections) and the
RoboticsInfrastructure clone (23m27s locally, ~2-3m on fast connections).
The database image (Dockerfile.database) builds in 27 seconds
and is independent of the other two — it is never a bottleneck.
What Lives Inside the Running Container
Running docker run --rm --entrypoint bash jderobot/robotics-academy:latest with du -sh against key directories reveals what is actually present on disk inside the container at runtime:
| Path Inside Container | Measured Size | Present at Runtime |
|---|---|---|
/ompl (OMPL source tree + build artifacts) |
1.5 GB | Yes — entire source and build directory left on disk |
/home/drones_ws/src (Aerostack2 source) |
114 MB | Yes |
/home/drones_ws/build (Aerostack2 CMake artifacts) |
346 MB | Yes |
/home/drones_ws/log (Aerostack2 colcon logs) |
2.8 MB | Yes |
/home/drones_ws/install (Aerostack2 runtime) |
52 MB | Yes — this is the only part needed |
/home/ws/src (RoboticsInfrastructure packages) |
2.8 GB | Yes — confirmed required: find /home/ws/install -type l returns symlinks pointing into src/. Deleting src/ breaks the install tree. |
/home/ws/build (ROS2 workspace build artifacts) |
119 MB | Yes |
/home/ws/log (ROS2 workspace colcon logs) |
2.9 MB | Yes |
/home/ws/install (ROS2 workspace runtime) |
54 MB | Yes — runtime install tree |
react_frontend/node_modules |
840 MB | Yes — only needed during build, not at runtime |
/opt/jderobot |
0 bytes (cleaned) | No — moved to other locations |
Image Efficiency Analysis
Running dive jderobot/robotics-academy:latest --ci produced the following result:
PASS: highestUserWastedPercent
PASS: lowestEfficiency
SKIP: highestWastedBytes (rule disabled by default)
Result: PASS [Total:3] [Passed:2] [Failed:0] [Warn:0] [Skipped:1]
The image passes dive’s default CI thresholds. However the highestWastedBytes rule — the rule that would flag the largest ghost layers — was skipped because it is disabled in the default configuration. This means the default dive --ci check is not sufficient to catch the largest sources of bloat in this image without custom threshold configuration. Enabling and tuning this rule will be part of the optimization deliverables.
How Code Actually Gets Executed
One of the most important things to understand before touching any Dockerfile is what the running container actually does at runtime. I had initially assumed Django was responsible for executing student code. Tracing through the codebase — with Javier helping clarify the architecture — showed that assumption was wrong, and getting it wrong would have broken the most critical part of the migration.
The actual flow is:
- The React frontend packages the student’s code into a Base64-encoded ZIP file.
- That ZIP is sent over WebSockets to port 7163, which belongs to the Robotics Application Manager (RAM) — a separate daemon.
- RAM receives it, clears
/workspace/code/, extracts the ZIP, and spawns asubprocess.Popen— eitherpython3 <entrypoint>for Python code, orcolcon build+ros2 launchfor C++/ROS 2.
Django just handles frontend routing and file writes. RAM is where execution actually happens.
This distinction matters directly for the Podman migration. Because student code runs under RAM’s UID via subprocess.Popen, any rootless container setup has to preserve that UID mapping correctly or volume writes will silently fail. The CDI requirement for GPU access follows from the same constraint — rootless execution cannot use the NVIDIA daemon runtime. Both of these are implementation problems for the coding period, not community bonding. The point here is that I now know exactly where the constraints come from.
The Telemetry Bridge
I also confirmed how ROS 2 simulation data reaches the browser.
There is no rosbridge_suite in the dependencies. Instead, each
exercise backend spawns a native rclpy node that pushes data
over WebSockets on port 2303 to the React CommsManager.
One thing flagged here that directly affects the multi-stage build:
there is a custom-patched websocket_server.py in the RAM source
tree that fixes an OPCODE_CONTINUATION bug in the upstream library.
A naive pip install websocket-server in the runtime stage would
silently overwrite this patch and break the telemetry pipeline.
This file needs explicit handling in the build — the exact strategy
will be documented in Week 1 of the coding period.
Camera Feeds and Wayland
One concern I had was whether migrating the display stack would
break drone camera feeds. After tracing the vision pipeline, the
answer is: the primary camera feeds encode frames as Base64 via
OpenCV and send them over WebSockets — no dependency on Xvfb
or VNC. Those feeds are safe.
The Gazebo simulation window is a different story — it does rely on the VNC pipeline. The X11-to-Wayland transition needs to account for that separately. Core camera feeds safe, full Gazebo desktop view is not a free migration.
Summary
Week 1:
- Pulled
jderobot/robotics-academy:latest(29.5 GB) andjderobot/robotics-database:latest(486 MB) - Set up NVIDIA Container Toolkit and confirmed Django on port 7164
- Kickoff sync with David Pascual-Hernández
Week 2:
- Pulled and profiled
jderobot/robotics-academy:latest— confirmed 29.5 GB, 30 layers - Ran
docker historyanalysis — full layer-by-layer size breakdown documented - Identified ghost layer pattern — RoboticsInfrastructure clone permanently inflating image
- Measured OMPL build time: 34 minutes 16 seconds on Ryzen 5 4600H
- Measured Aerostack2 build time: 13 minutes 52 seconds (20 packages, correct COLCON_IGNORE)
- Measured React frontend build time: 3 minutes 20 seconds (yarn install + webpack production)
- Measured IndustrialRobots double colcon build: 3 minutes 8 seconds (59 packages, both passes)
- Confirmed live filesystem waste via
du -shinside running container - Traced execution pipeline: Django → RAM →
subprocess.Popen - Confirmed
--userns=keep-idis required for rootless Podman - Found custom-patched
websocket_server.py— flagged as risk for multi-stage build - Confirmed primary camera feeds bypass X11 — Gazebo VNC pipeline requires separate handling
- Ran
dive --ciimage efficiency analysis — flagged disabledhighestWastedBytesrule
What’s Next
Week 1 of the coding period starts tomorrow. The baseline is fully documented — every layer has a measured size, every expensive component has a measured build time, and the live filesystem waste is confirmed.
The before-baseline is locked. Every optimization will be measured against these exact numbers.
Part of my GSoC 2026 work with JdeRobot. Project tracked at github.com/TheRoboticsClub/gsoc2026-Kartik_Jangid.