Internship Progress Week 3
Internship Progress Week 3
What I did this week
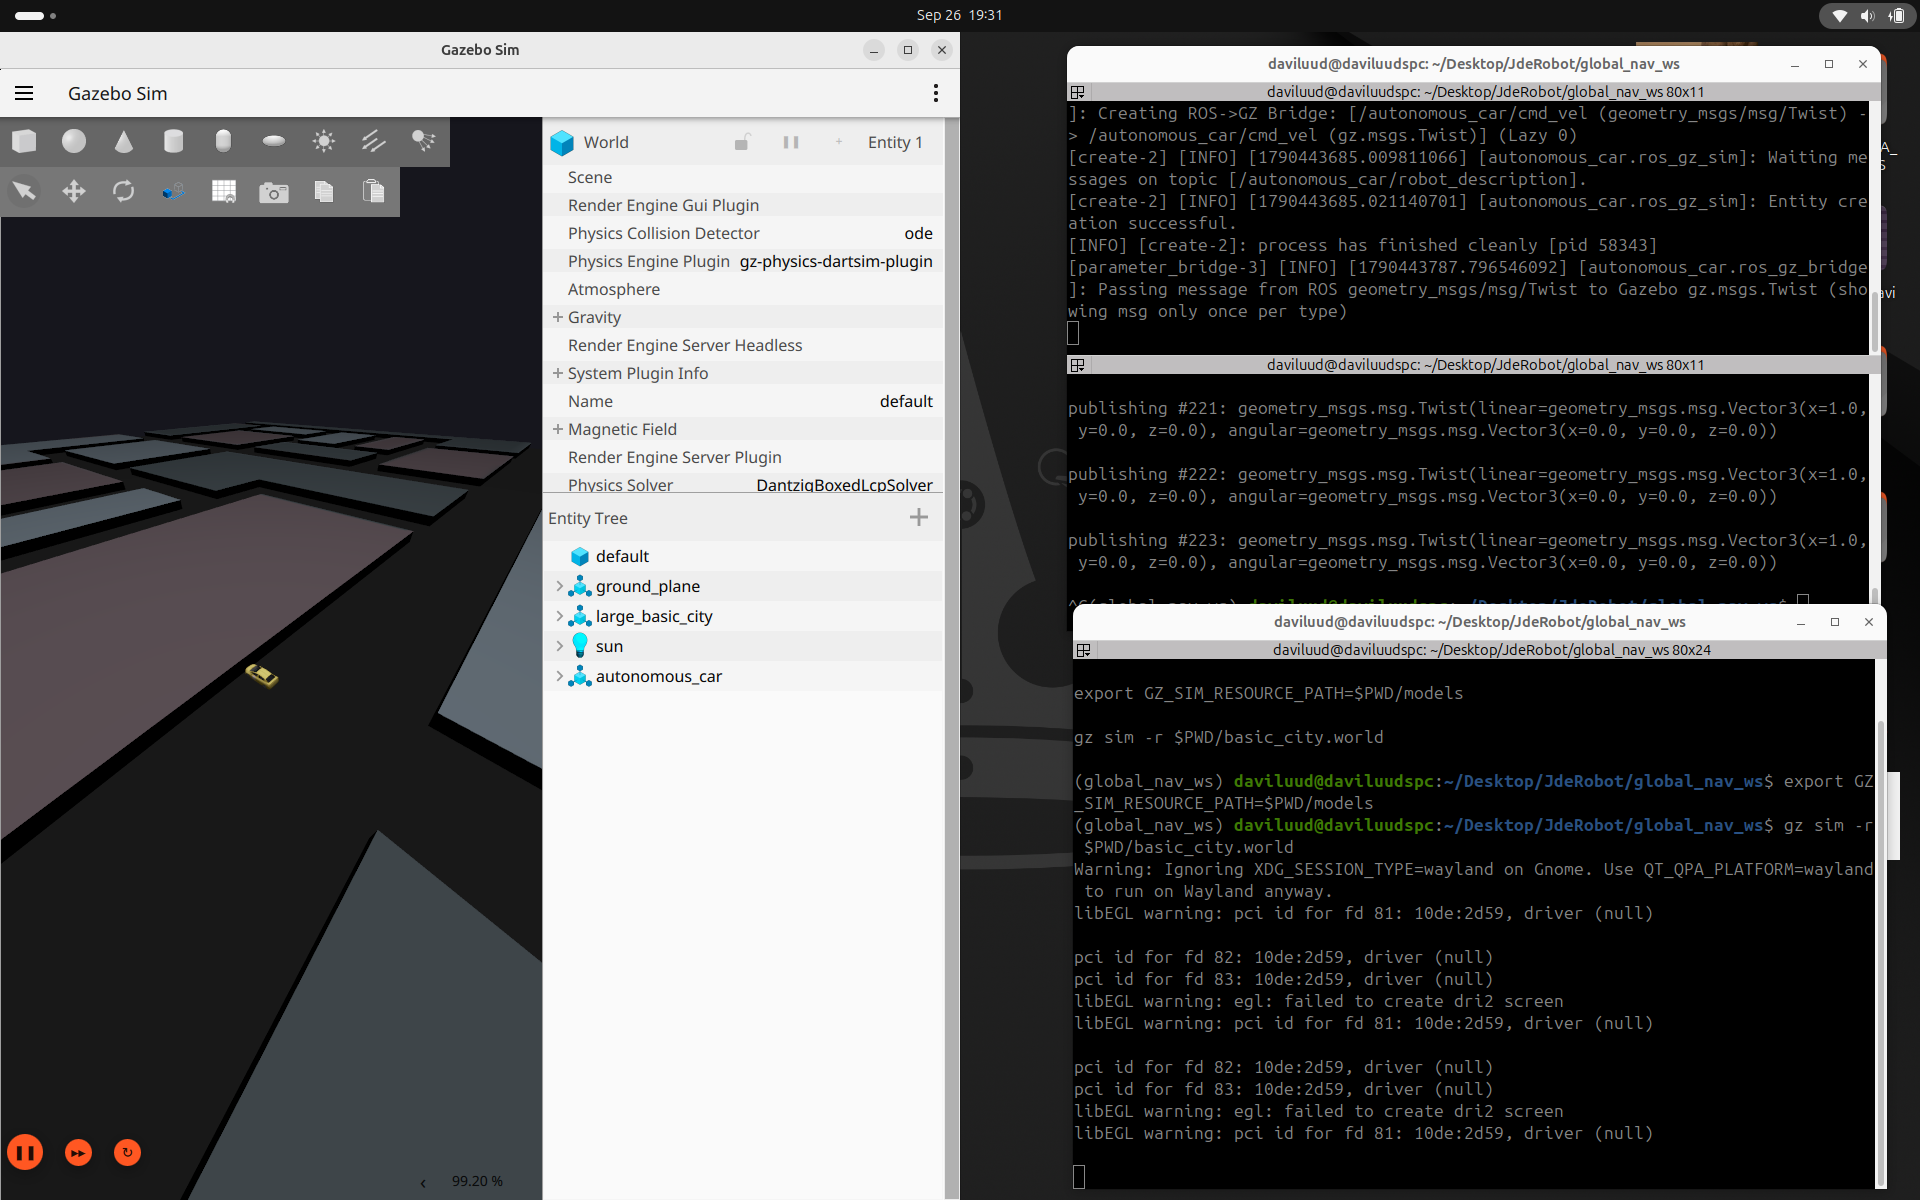
This week I moved the UniBotics Global Navigation environment to a local setup so I can work directly with ROS 2, without relying on HAL or WebGUI.
I created a clean environment with ROS 2 Jazzy + Gazebo Harmonic using Pixi, and imported the main elements from the UniBotics exercise:
- the City Large world,
- the
autonomous_car, - and the LiDAR setup.
The robot is now running locally in Gazebo and can be controlled directly from ROS 2.
Next steps
The next step is to launch Nav2 in this environment and use it as the expert planner.
From there, the goal is to start recording the first dataset samples for the Imitation Learning pipeline:
1
local map + local goal -> expert path
This post is licensed under CC BY 4.0 by the author.