Coding Week 3 — PyTorch Out, CUDA Wheels In, Protobuf Untangled
Week 2 left three items open: two unpinned CUDA wheel versions, the C++ ONNX Runtime header version gap, and a full exercise test run on Dockerfile.dependencies_humble. The first and third are closed this week. The multi-stage build, originally slated to begin this week, moves to next week. PR #3863 is merged.
The Dependency Swap
PyTorch was installed in Dockerfile.dependencies_humble with full CUDA 12.8 support. It is not imported anywhere in RoboticsAcademy or RoboticsInfrastructure — it was only there because it happened to bundle the CUDA shared libraries that onnxruntime-gpu needs at runtime.
The replacement is the seven CUDA 12.8 wheels that onnxruntime-gpu==1.22.0 actually declares as runtime dependencies:
RUN python3.10 -m pip install --no-cache-dir \
    nvidia-cuda-runtime-cu12==12.8.90 \
    nvidia-cublas-cu12==12.8.4.1 \
    nvidia-cudnn-cu12==9.10.2.21 \
    nvidia-nvjitlink-cu12==12.8.93 \
    nvidia-cuda-nvrtc-cu12==12.8.93 \
    nvidia-curand-cu12==10.3.10.19 \
    nvidia-cufft-cu12==11.4.1.4
All seven are hard-pinned. A build-time ldconfig step registers the pip-installed .so files with the system linker so they are visible to onnxruntime-gpu regardless of shell environment (sourcing a ROS 2 workspace cannot interfere).
Why is the image size reduction only ~1 GB? PyTorch at ~4.7 GB was removed, but the seven CUDA runtime wheels that replaced it add back a meaningful portion of that size. The net gain is the training-only components of PyTorch that were never needed — the wheels above are the runtime-only slice.
| Image | Size |
|---|---|
jderobot/robotics-academy:test (full) |
18.2 GB |
jderobot/robotics-applications:dependencies-humble (base) |
12.8 GB |
The Protobuf Issue
After the initial build, Javier caught a crash in Gazebo Harmonic exercises:
TypeError: Descriptors cannot be created directly.
Diagnosing it took three steps.
Phase 1 — What does onnxruntime-gpu actually declare?
Running importlib.metadata.distribution('onnxruntime-gpu').metadata.get_all('Requires-Dist') inside the container reads the wheel’s declared dependencies directly. This showed that onnx was not in the Requires-Dist list — it had been added manually and unnecessarily. It was a second, silent source of the same protobuf conflict.
Phase 2 — What versions are actually resolved?
pip list --format=columns | grep nvidia captured the exact versions pip had resolved for the seven CUDA wheels. Those exact versions were then pinned in the Dockerfile rather than letting pip re-resolve on every build.
Phase 3 — Why does the crash happen?
The traceback pointed to gz/msgs10/time_pb2.py failing at import with the descriptor error. Gazebo Harmonic’s gz.msgs10 Python bindings were generated with protoc 3.x. The C++ extension enforcement was introduced in protobuf 4.x, and onnxruntime-gpu pulls in bare protobuf as a transitive dependency, which pip resolves to the latest version (7.35.0 at the time of testing).
Pinning protobuf<4 would have fixed the immediate crash but created a version floor that would break future onnxruntime-gpu upgrades. The correct fix is Google’s own documented workaround:
ENV PROTOCOL_BUFFERS_PYTHON_IMPLEMENTATION=python
This forces the pure-Python parser, which is forward-compatible with all protoc versions. The importlib.metadata inspection in Phase 1 was what made this clear — without it, pinning protobuf would have looked like the obvious fix.
Testing
All exercises were verified on the patched image before the PR was merged:
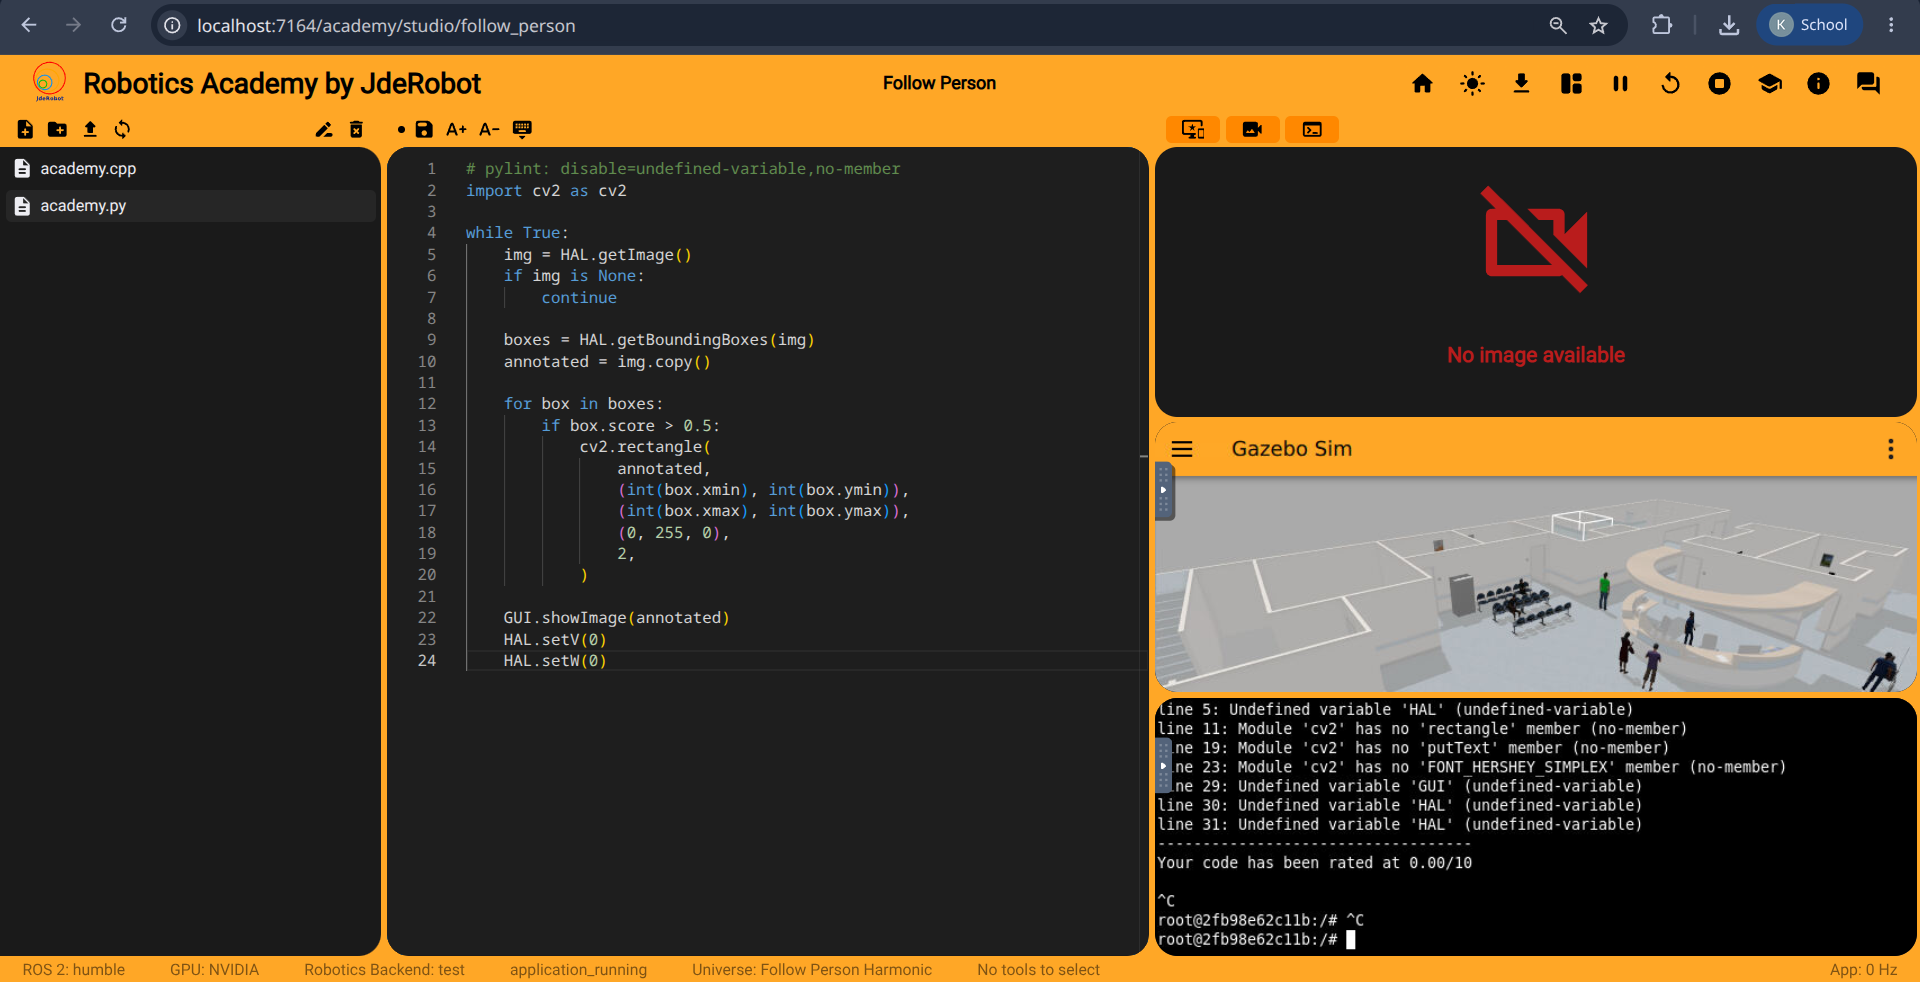
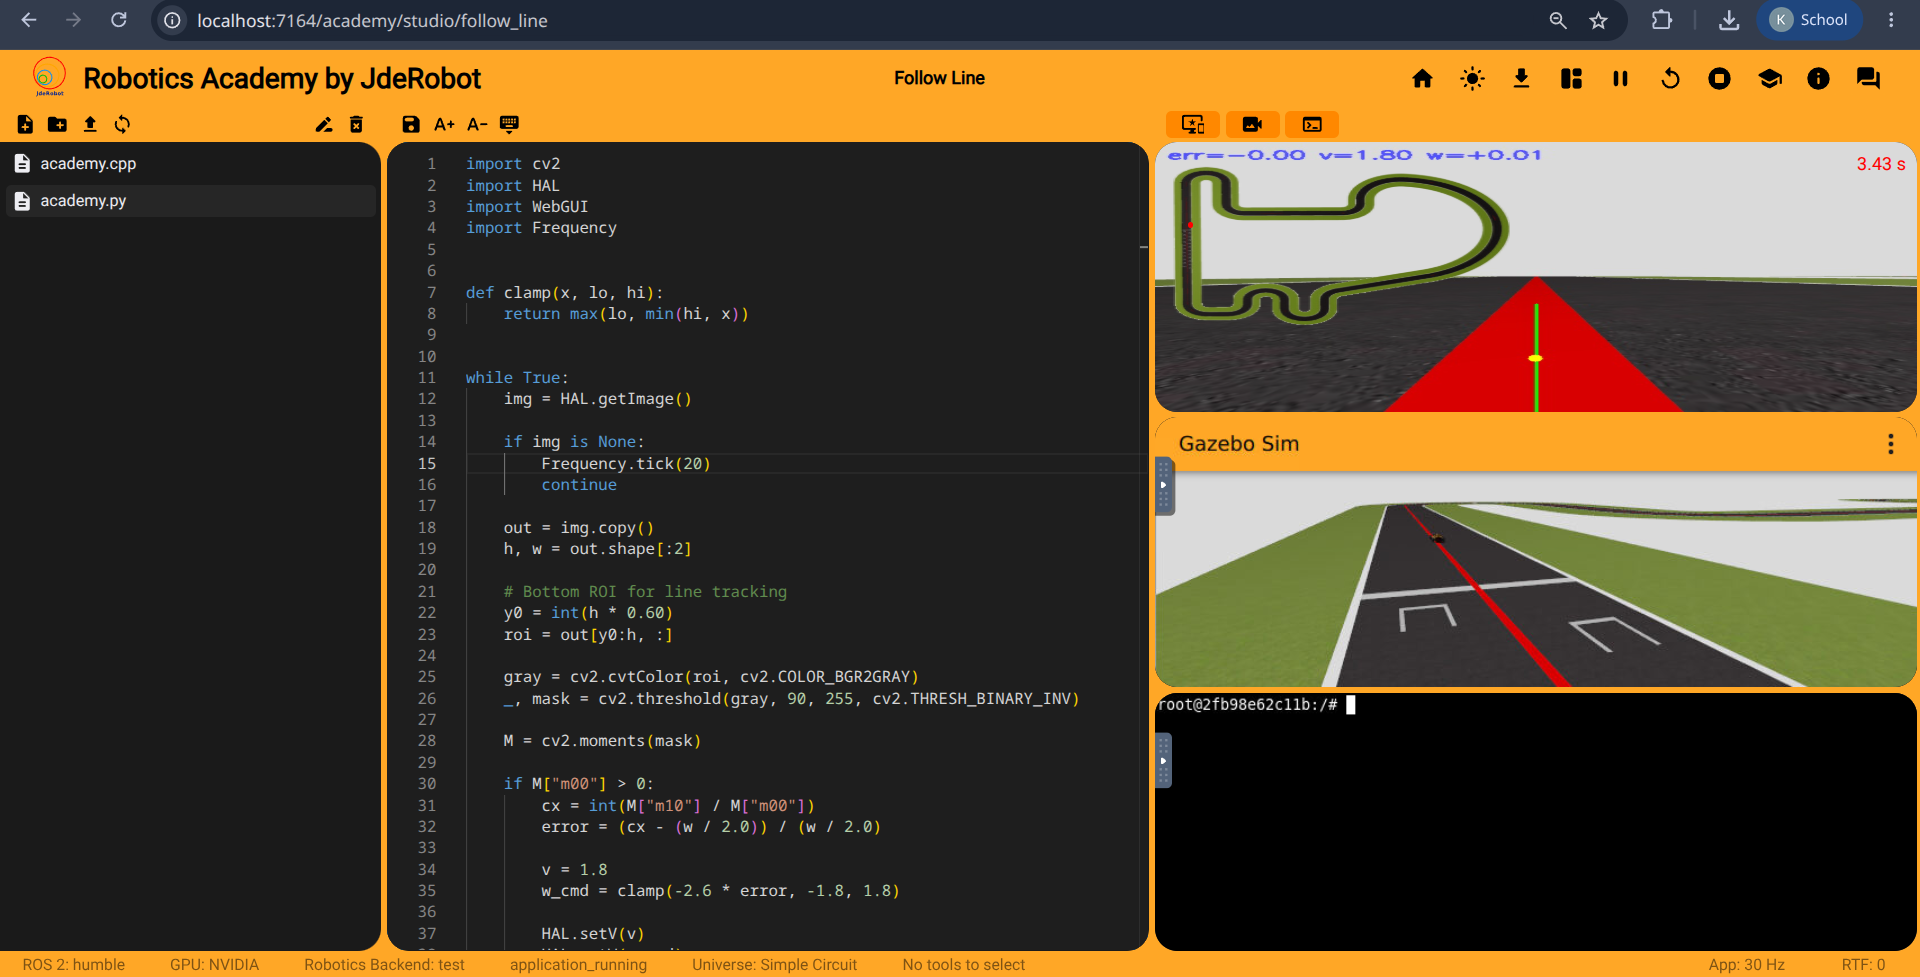
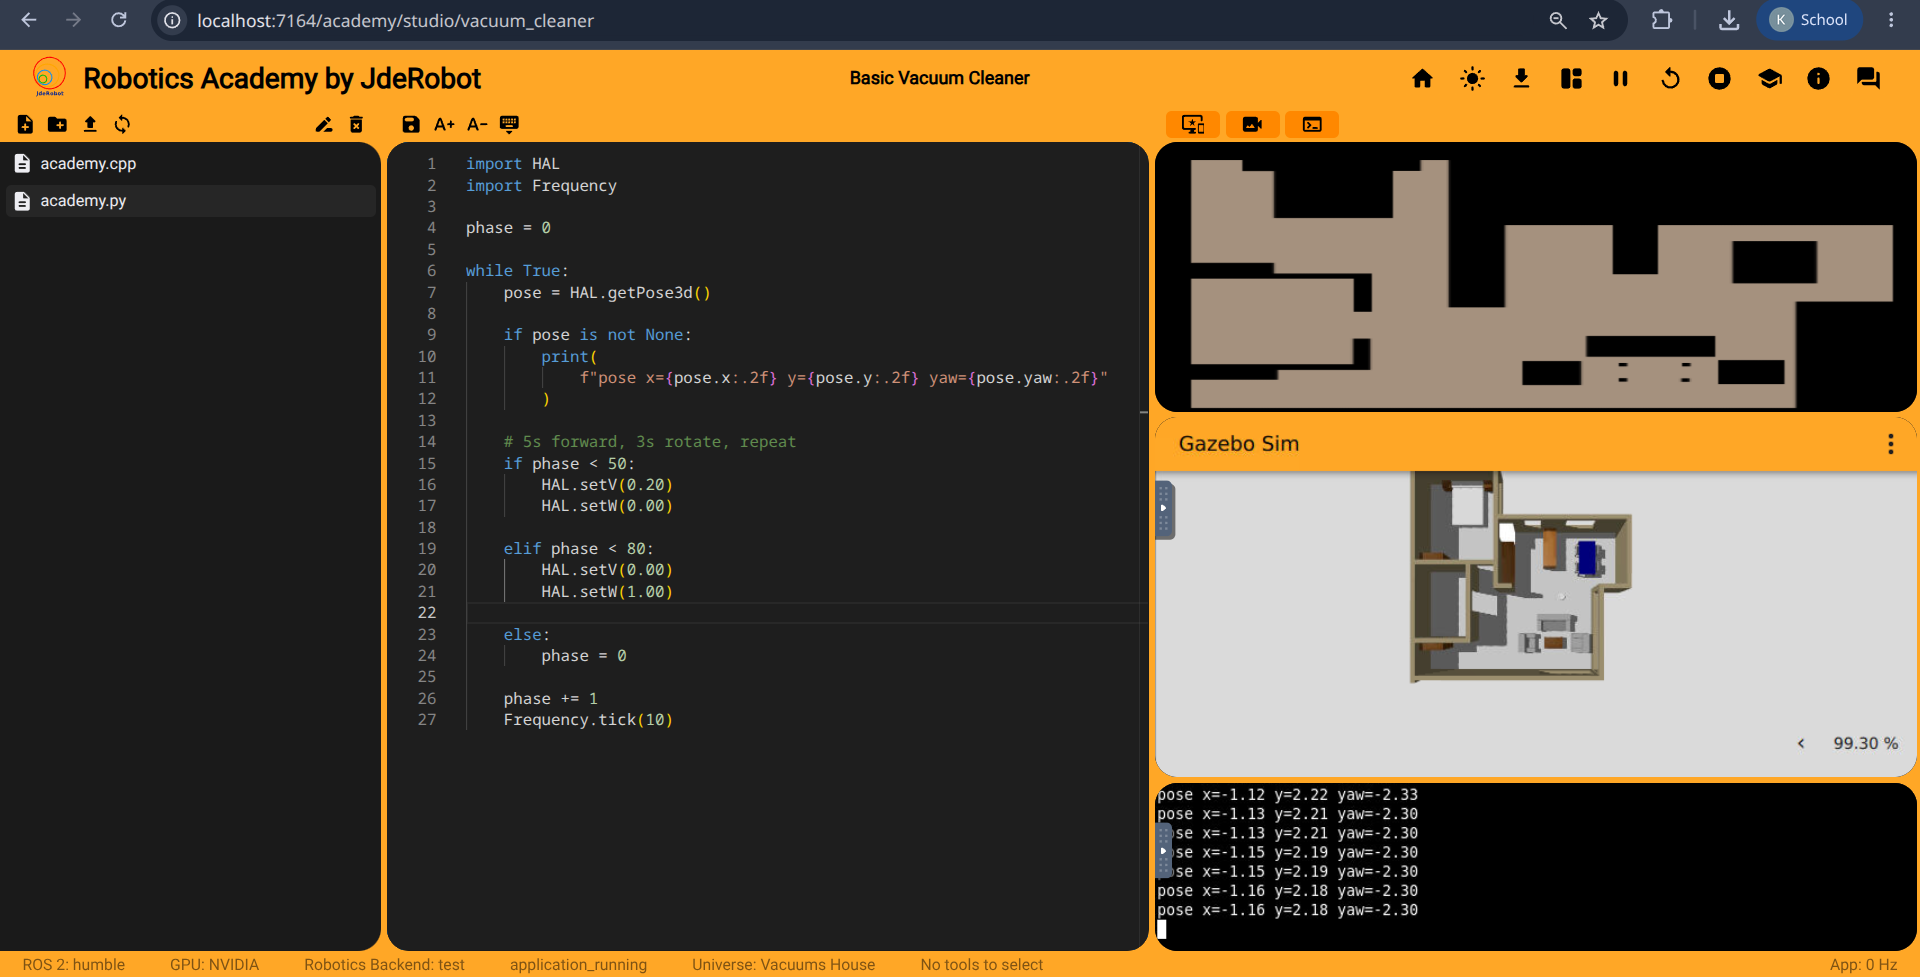
| Exercise | Simulator | Result |
|---|---|---|
| Follow Person | Gazebo Harmonic | World loads, camera feed and person detection working |
| Follow Line | Gazebo Classic | Passing |
| Basic Vacuum Cleaner | Gazebo Classic | Passing |
GPU inference confirmed inside the container:
['TensorrtExecutionProvider', 'CUDAExecutionProvider', 'CPUExecutionProvider']
What is Next
Two targets for Week 4:
Multi-stage build — split Dockerfile.dependencies_humble into a builder stage and a runtime stage so build-only tools and intermediate artifacts do not land in the shipped image.
Gazebo audit — David flagged that the image carries two Gazebo installations but only one is needed. Week 4 will identify which is redundant and what removing it saves.
Part of my GSoC 2026 work with JdeRobot. Project tracked at github.com/TheRoboticsClub/gsoc2026-Kartik_Jangid.