Coding Period Week 7 (July 10 ~ July 16)
This week was heavily focused on complex block architecture for the Obstacle Avoidance exercise and refining the core VisualCircuit editor features, specifically around block handling, downloading, and local storage.
🎯 The Main Goals for the Week
- Make the final showcase video for the Obstacle Avoidance exercise.
- Allow multiple downloads of the same block into the Downloads palette.
- Improve and address issues raised by the mentor in both the
VisualCircuitandVisualCircuit-resourcesrepositories. - Improve the storage of downloaded blocks (Currently exploring local file storage architecture).
🏎️ Engineering the Obstacle Avoidance Architecture
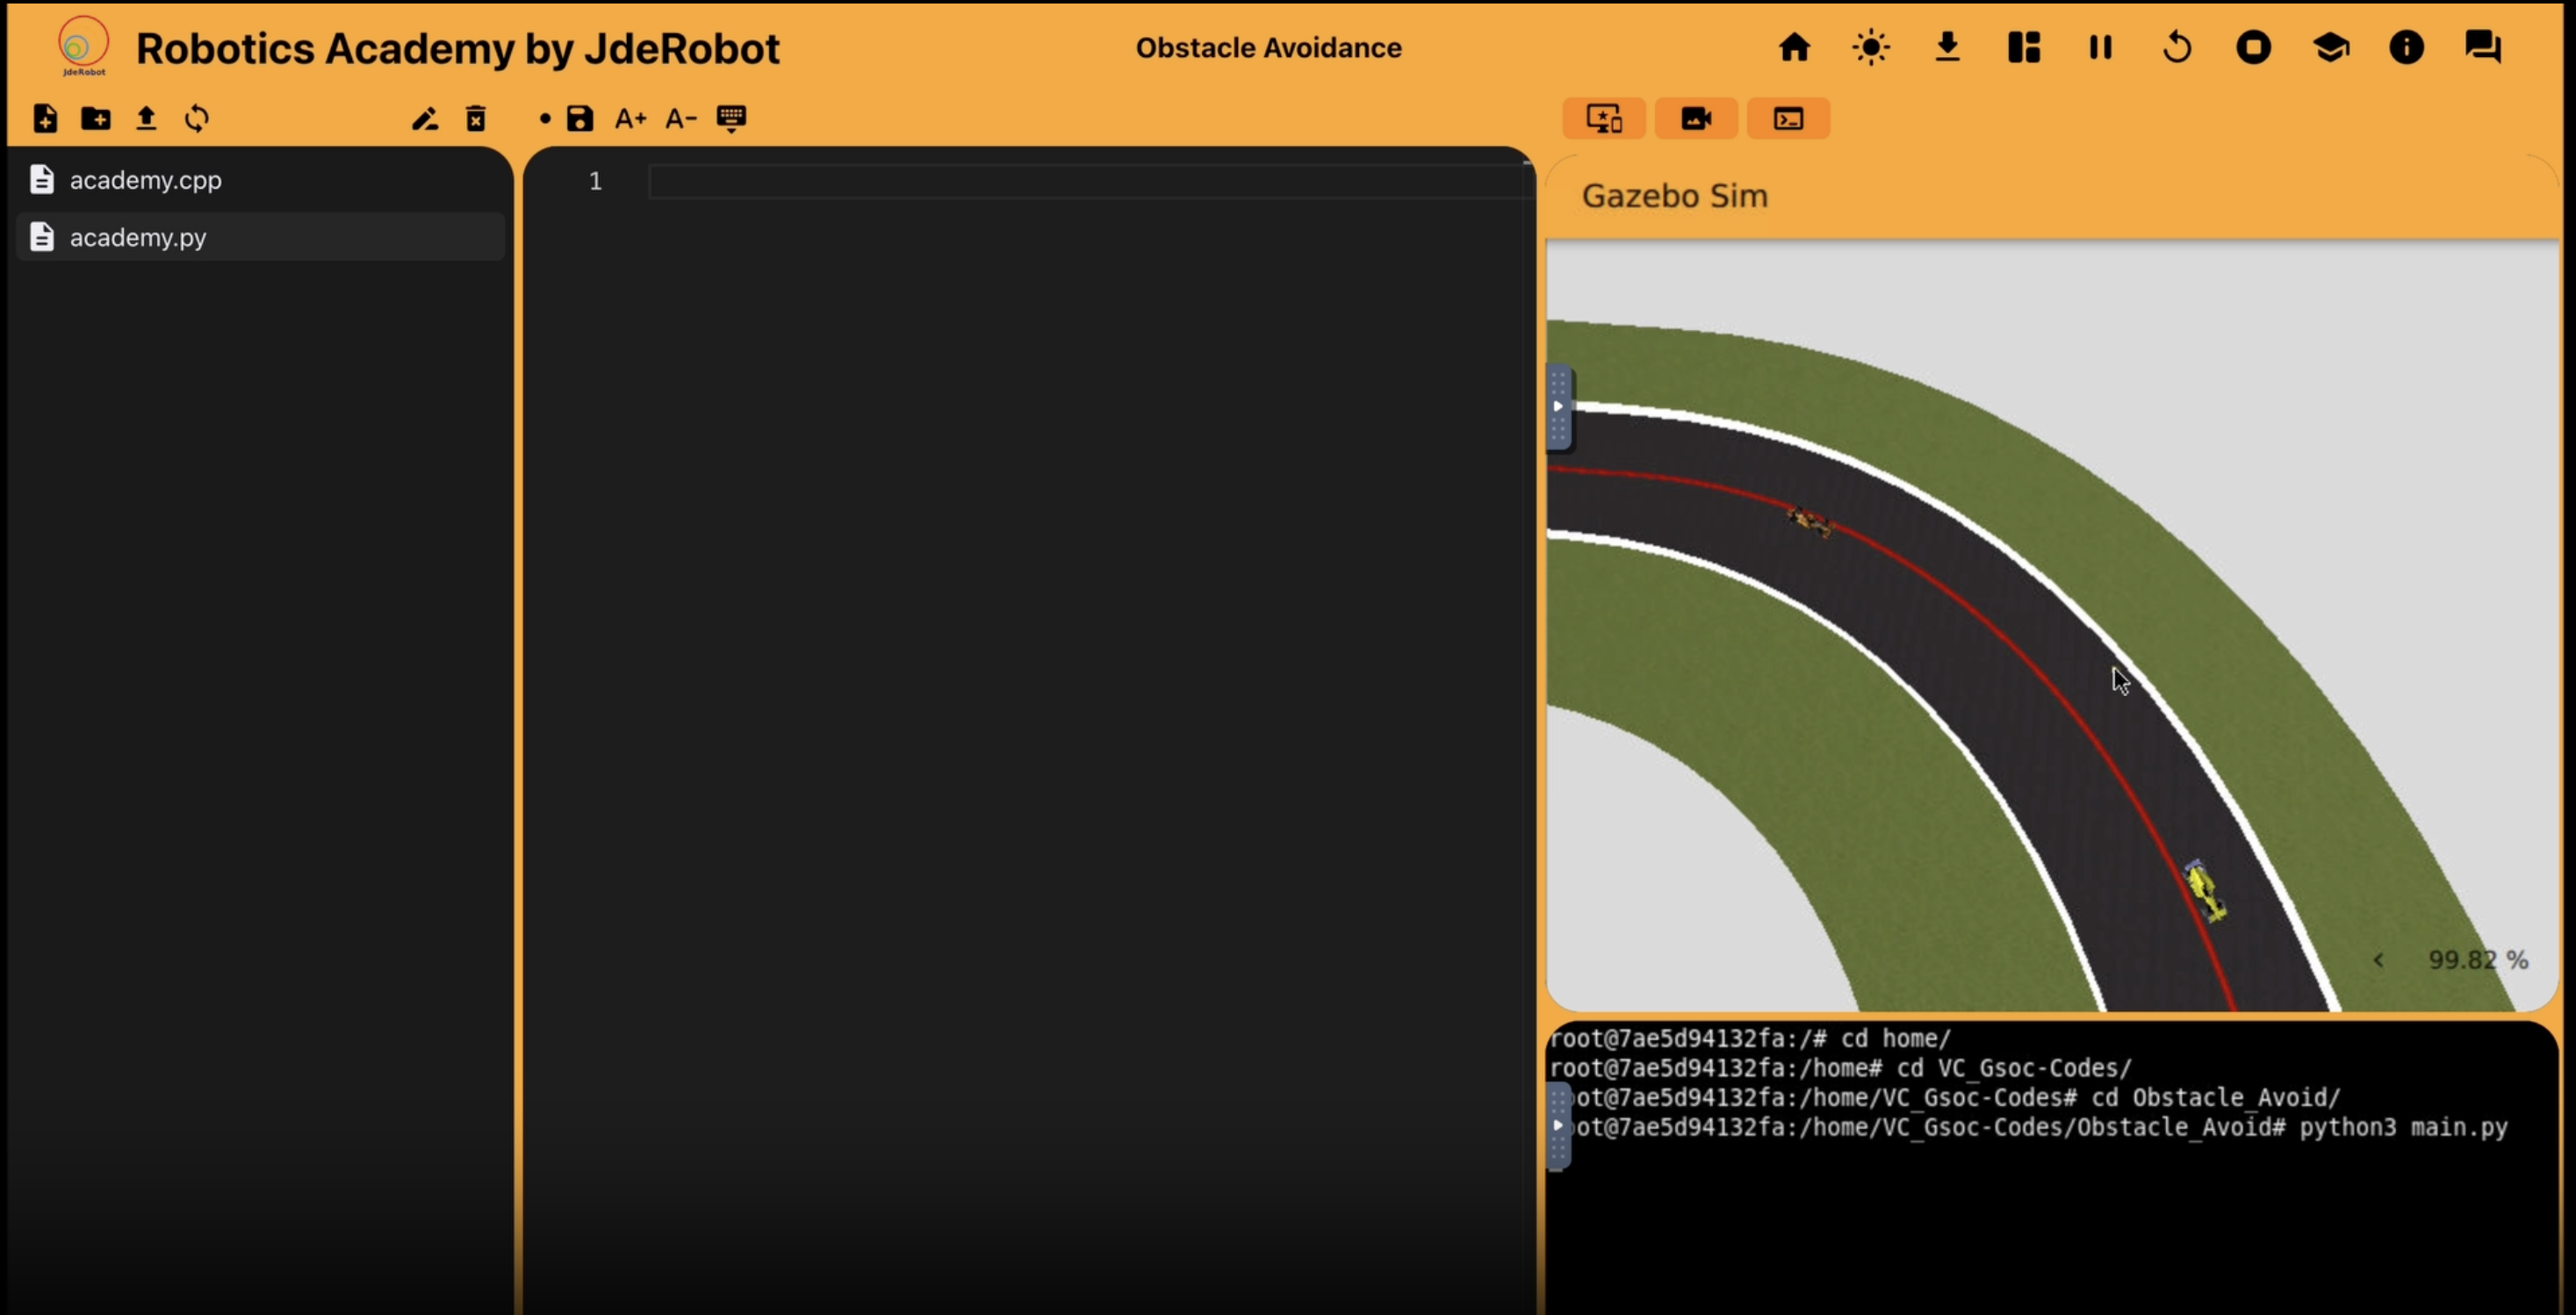
I spent the majority of my time this week designing and debugging the blocks for the Obstacle Avoidance exercise.
I initially started with the original, working Robotics Academy code as a single, massive block where laser reading, odometry, target tracking, force calculation, and motor commands were all bundled together. That worked perfectly because everything ran in a single loop using HAL and WebGUI.
I then tried to split it into 3 blocks (Sensor Input, Decision/Force Calculation, Motor Output), but I immediately ran into the parallel execution issue again—VisualCircuit blocks run simultaneously, not sequentially, so data passing through the wires has to be perfectly timed.
The Final 7-Block Structure
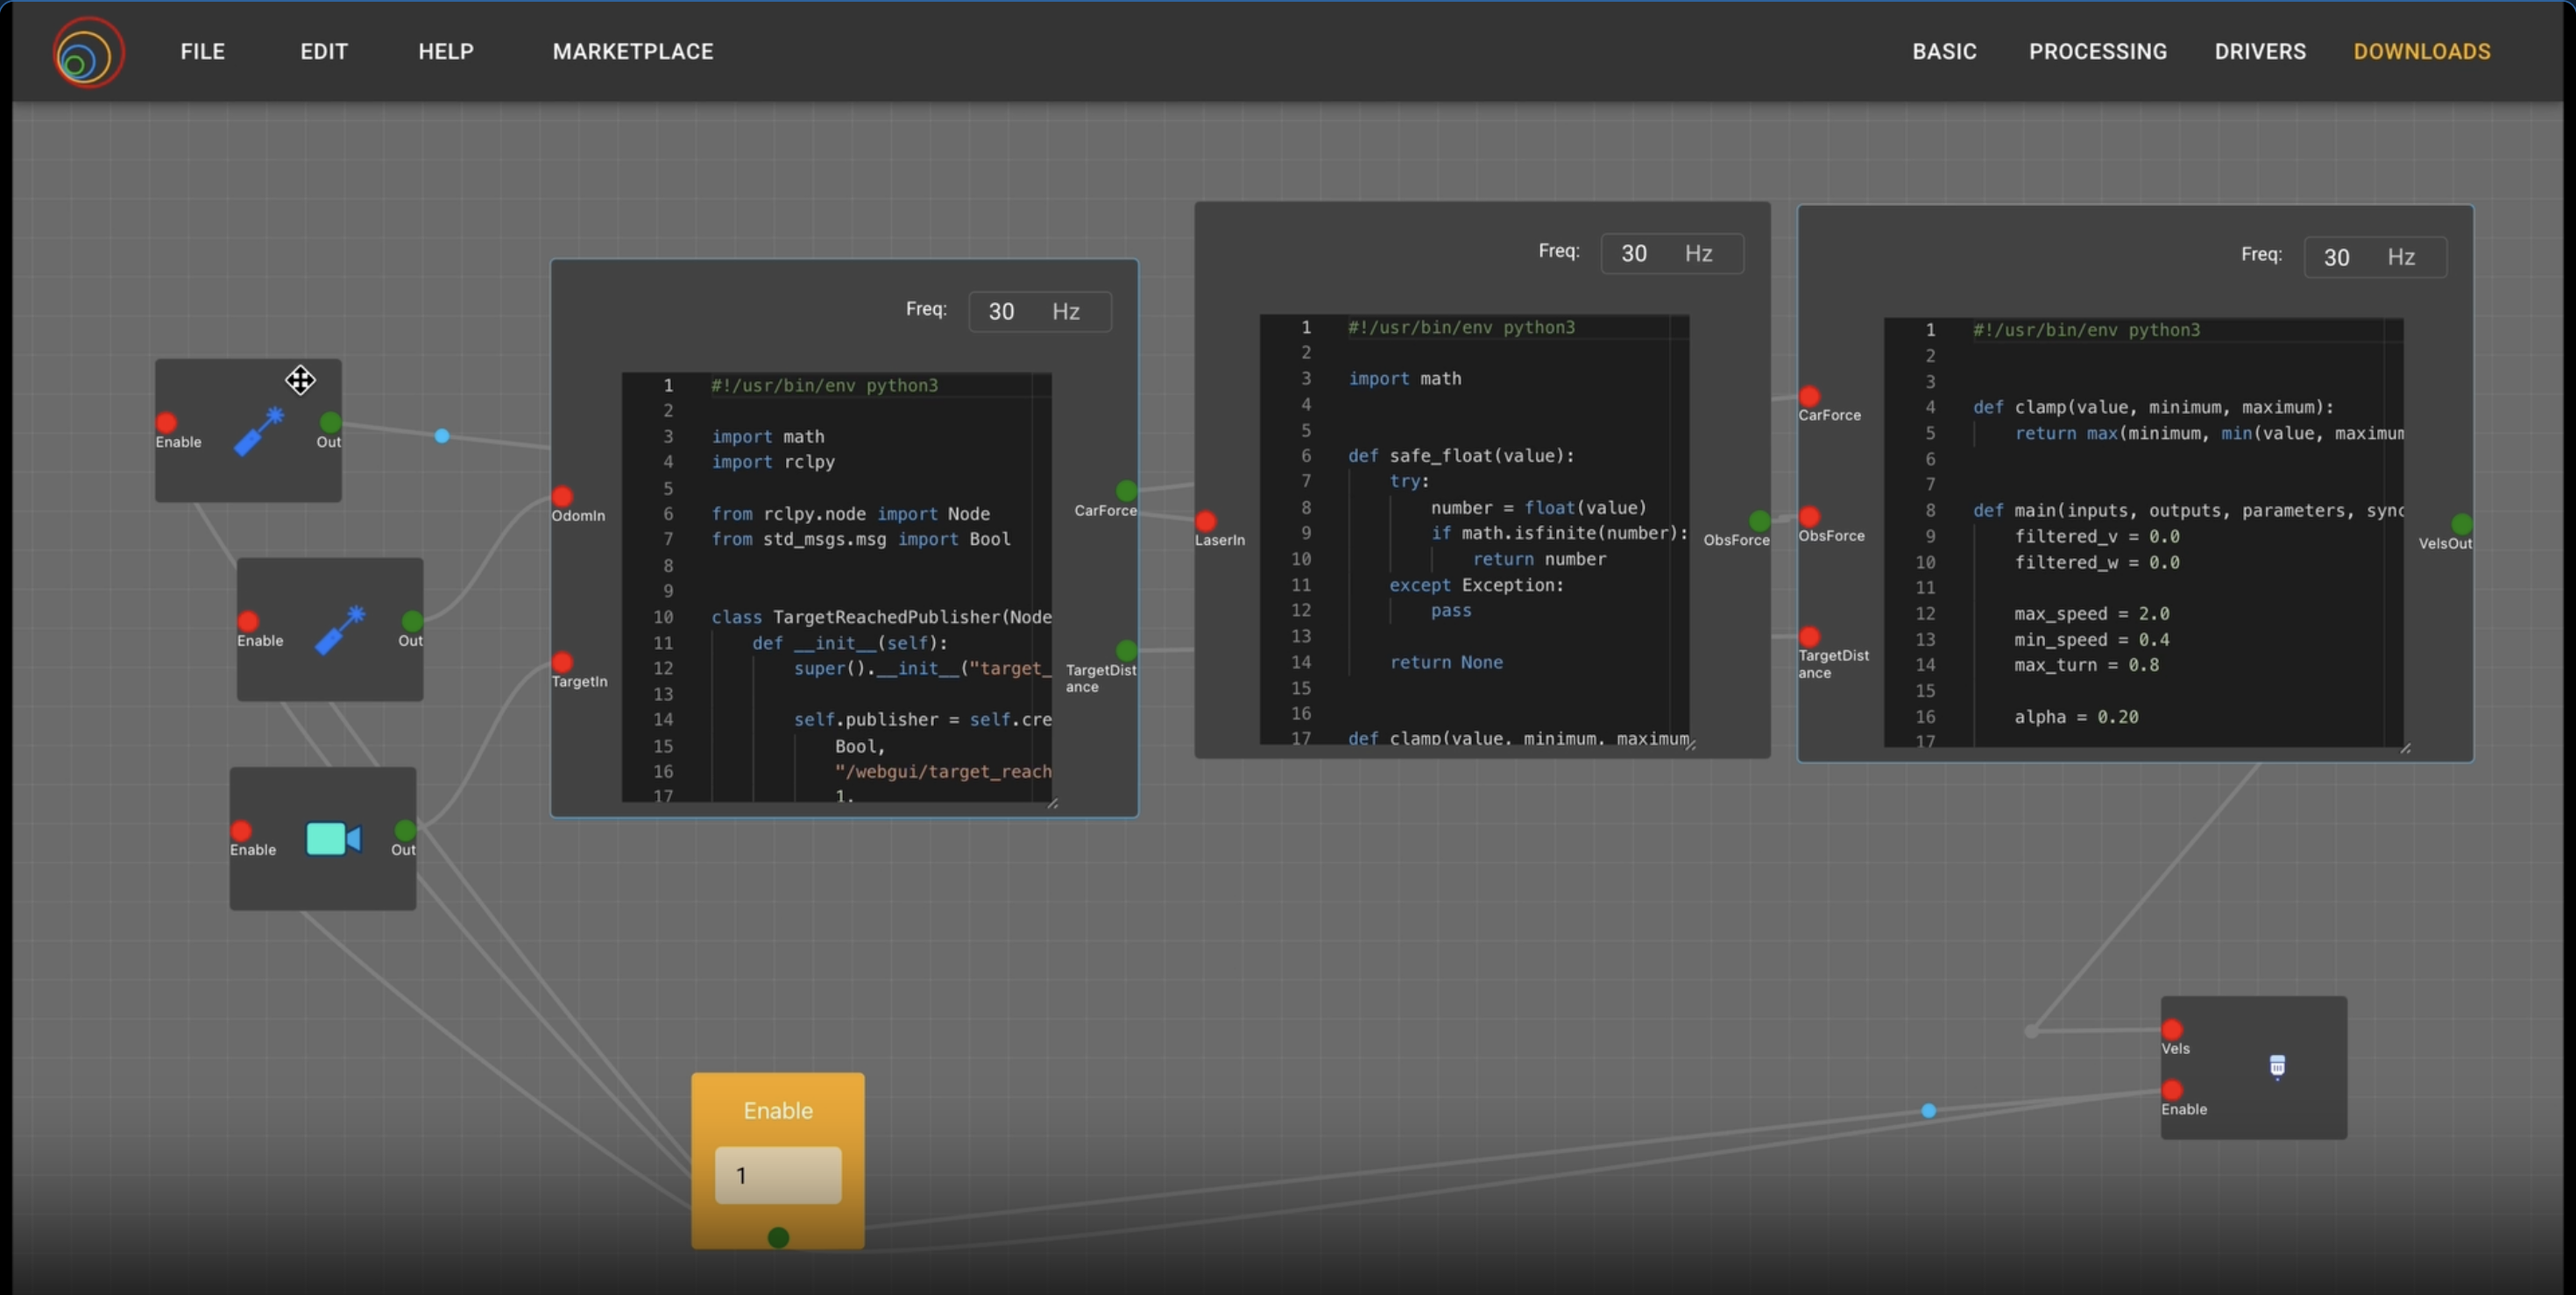
To create a truly robust and modular system, I expanded the architecture into a 7-block structure:
- ROS2LaserScan1001: Reads
/f1/laser/scan - ROS2LaserScan1002: Reads
/odom - ROS2Camera2001: Reads
/webgui/current_target - Code_1: Calculates the target attraction force.
- Code_2: Calculates the obstacle repulsion force.
- Code_3: Mixes both forces into a final velocity vector.
- ROS2MotorDriver1001: Publishes the final output to
/cmd_vel.
🧗 Issues Faced
During the development of the Obstacle Avoidance blocks, I faced several frustrating physics and communication issues:
- Block Timing & Ports: Wrong port connections and blocks not sharing values at the exact right time due to the parallel execution.
- Unstable Physics: Unstable steering, extreme deviations near obstacles, and the robot either over-turning or under-turning.
The Solutions: I fixed these by rigorously checking the live ROS topics, precisely matching the VisualCircuit input/output names, and manually tuning the obstacle force and steering gains. Finally, I added a specific “front-distance” logic so the robot intelligently slows down and turns harder when an obstacle is directly dead ahead.
🛠️ VisualCircuit Core Improvements & Mentor Feedback
1. Removing the Wire Constraint
Based on discussions and feedback from my mentor, I addressed an annoying constraint in the VisualCircuit editor: previously, no single block could exist without being attached to wires. I successfully removed this restriction, allowing blocks to be placed freely on the canvas without immediately requiring wire attachments!
2. Allowing Multiple Downloads
A major UI issue with the Marketplace was that you could only download a block once. If you wanted multiple instances of the same custom block, you were stuck. I implemented a counter system that now successfully tracks and allows multiple downloads of the exact same block from the Marketplace into your local Downloads folder!
3. The Local Storage Architecture (Work in Progress)
I have been working on improving how downloaded blocks are stored. My code is currently ready to store the downloaded blocks directly into a local file within VisualCircuit.
However, I hit an architectural crossroads that I need to resolve: When we populate the Downloads sidebar, do we fetch from the original Marketplace endpoint, or do we fetch from the new Local Storage? If we fetch from Local Storage, I will need to engineer a new local registry system just for tracking locally stored files. I plan to discuss this with my mentors to finalize the best approach!
🤝 Mentor Meeting
We had a highly productive sync this week to review the massive architectural changes. We discussed the logic behind removing the wire constraints in the UI, reviewed the new multiple-download tracking, and had an in-depth conversation about the Local Storage crossroads to determine our final path forward for the registry fetch system!